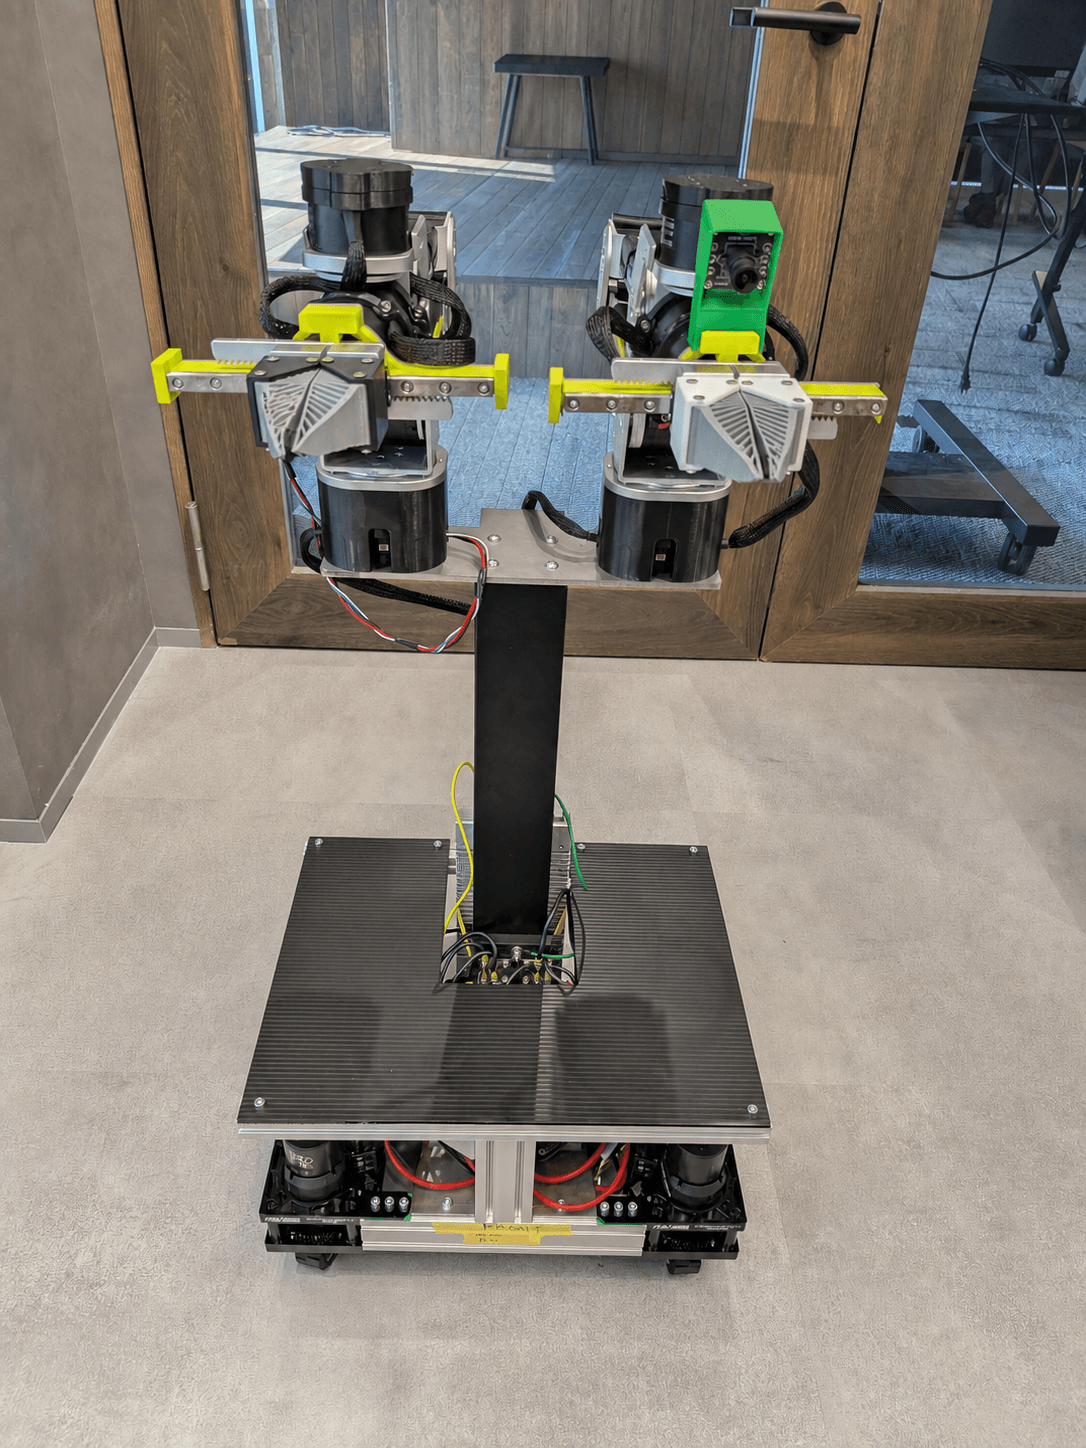
Open-source dual-arm mobile manipulator (semi-humanoid configuration), MY-0

PHYSICAL AI RESEARCH

MY-0

Open-source design across the whole platform. Build it yourself from about US$6,300 — or order a fully assembled, tested unit from approximately US$12,700.

Platform Configuration

A dual-arm robot built on an omnidirectional base

The semi-humanoid layout pairs two arms on the upper body with an omnidirectional mobile base below, enabling low-cost real-world testing of bimanual tasks for humanoid VLA and imitation learning research.

01

Open-source arms in a dual-arm setup

Two reBot Arm B601-DM arms are mounted on 45-degree brackets around a shared central workspace.

02

YOR-based omnidirectional mobility

YOR (Your Own Robot) is an open-source mobile manipulator combining an omnidirectional base, a vertical lift, and two arms. MY-0 builds on its base architecture and uses reBot Arm B601-DM arms.

03

From simulation to the real robot

Use the published URDF and meshes as a starting point for MuJoCo or NVIDIA Isaac Sim workflows. Test controls and tasks in simulation, then evaluate them on the physical robot for Sim-to-Real research.

Specifications & Dimensions

Technical Specifications & Engineering Drawings

Verified nominal specifications and official CAD dimensions of MY-0.

Dual-arm manipulation

reBot Arm B601-DM × 2

Degrees of freedom6 + 1 per arm (6-axis + 1 gripper)
Reach767 mm per arm
Payload1.5 kg per arm
Repeatability±0.2 mm per arm

Omnidirectional mobile base

Built on the open-source YOR base

Drive modules4 × REV 3in MAXSwerve

Each wheel steers and drives independently for forward, lateral, and rotational movement.

Drive motors4 × NEO Vortex

Per motor: 12 V nominal, 6,784 rpm free speed, 3.6 N·m stall torque, and 640 W peak output.

Steering motors4 × NEO 550

UltraPlanetary reduction ratio approx. 46.42:1; 8 SPARK Flex controllers across four modules.

Dimensions & Mounting References

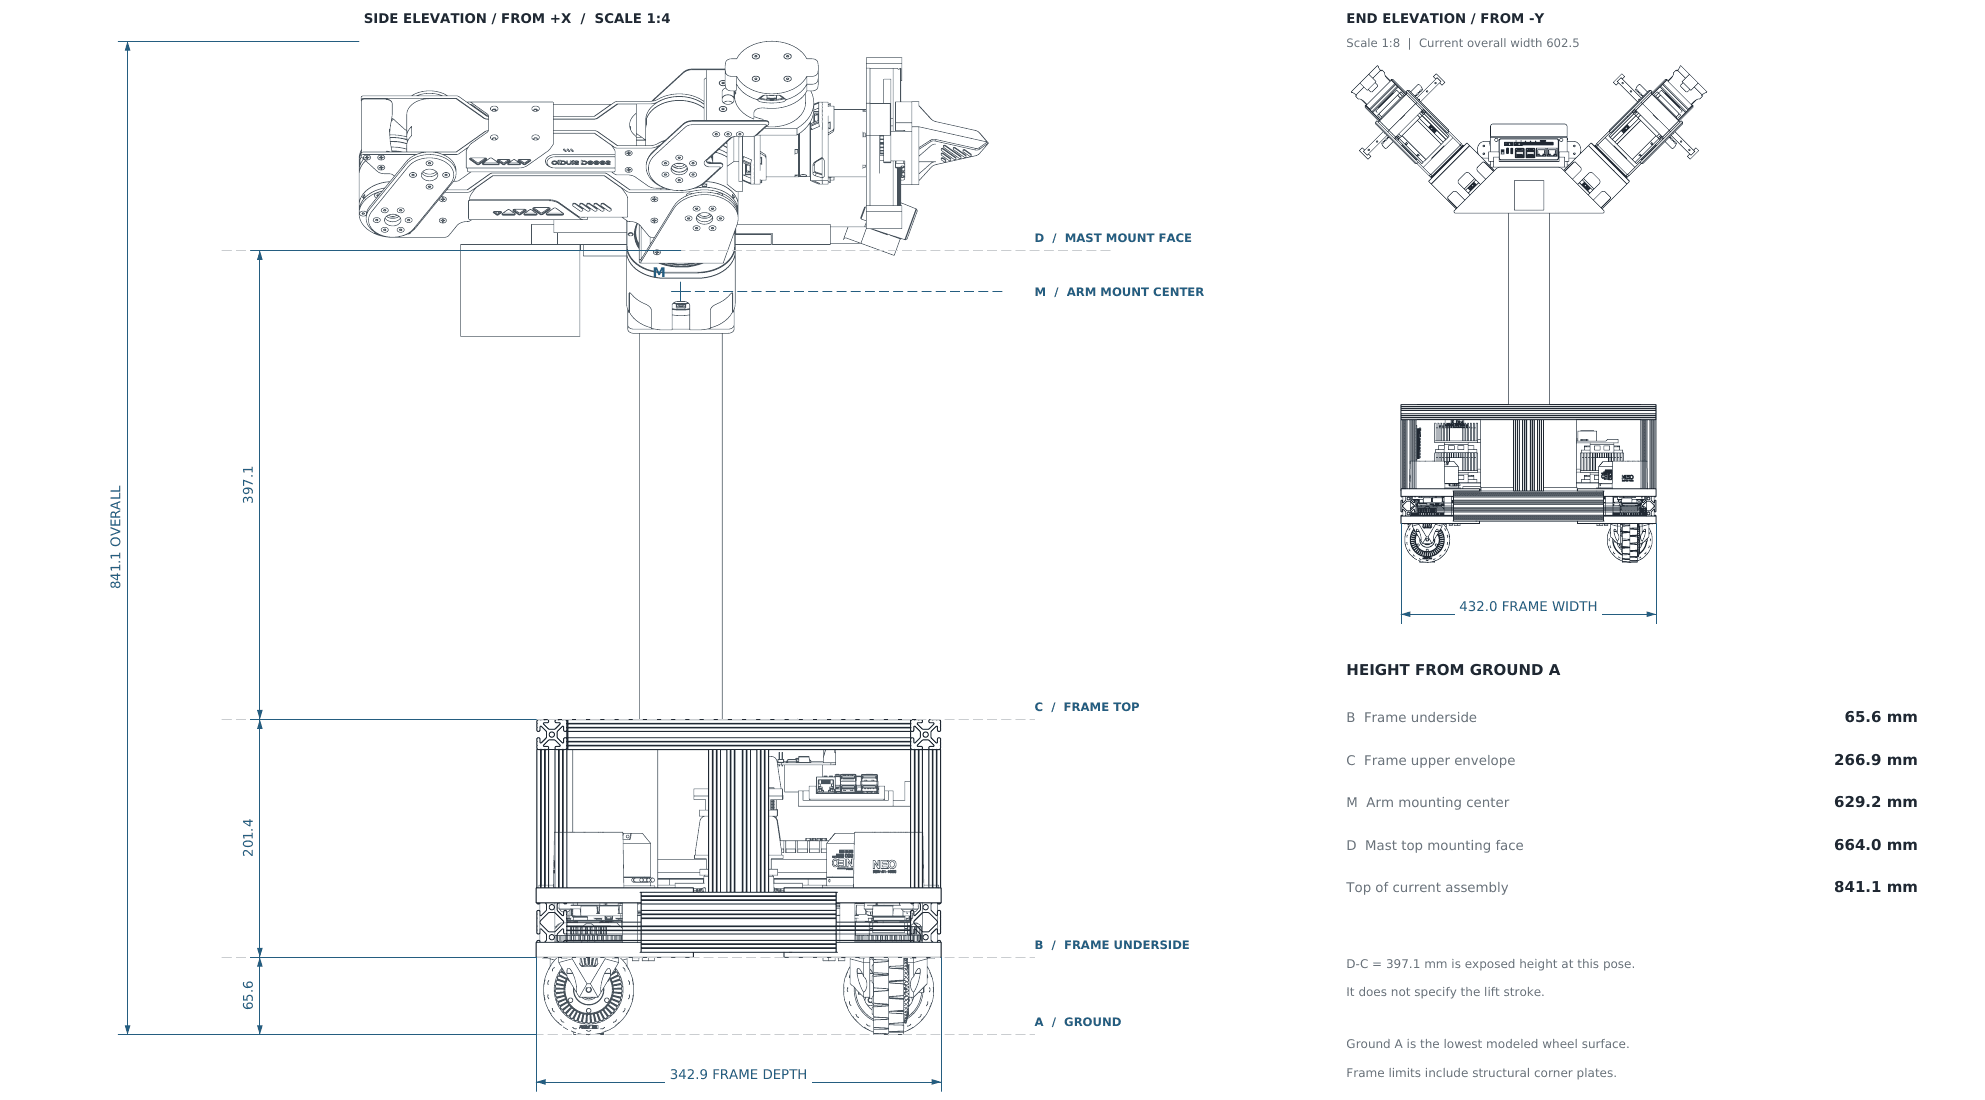
Overall height (current assembly)
841.1 mm

Height from ground reference A to the top of the assembly in the shown pose.

Arm span (folded)
602.5 mm

Outer span of the arms in their folded pose.

Overall depth (shown pose)
532.8 mm

Front-to-back depth in the pose shown.

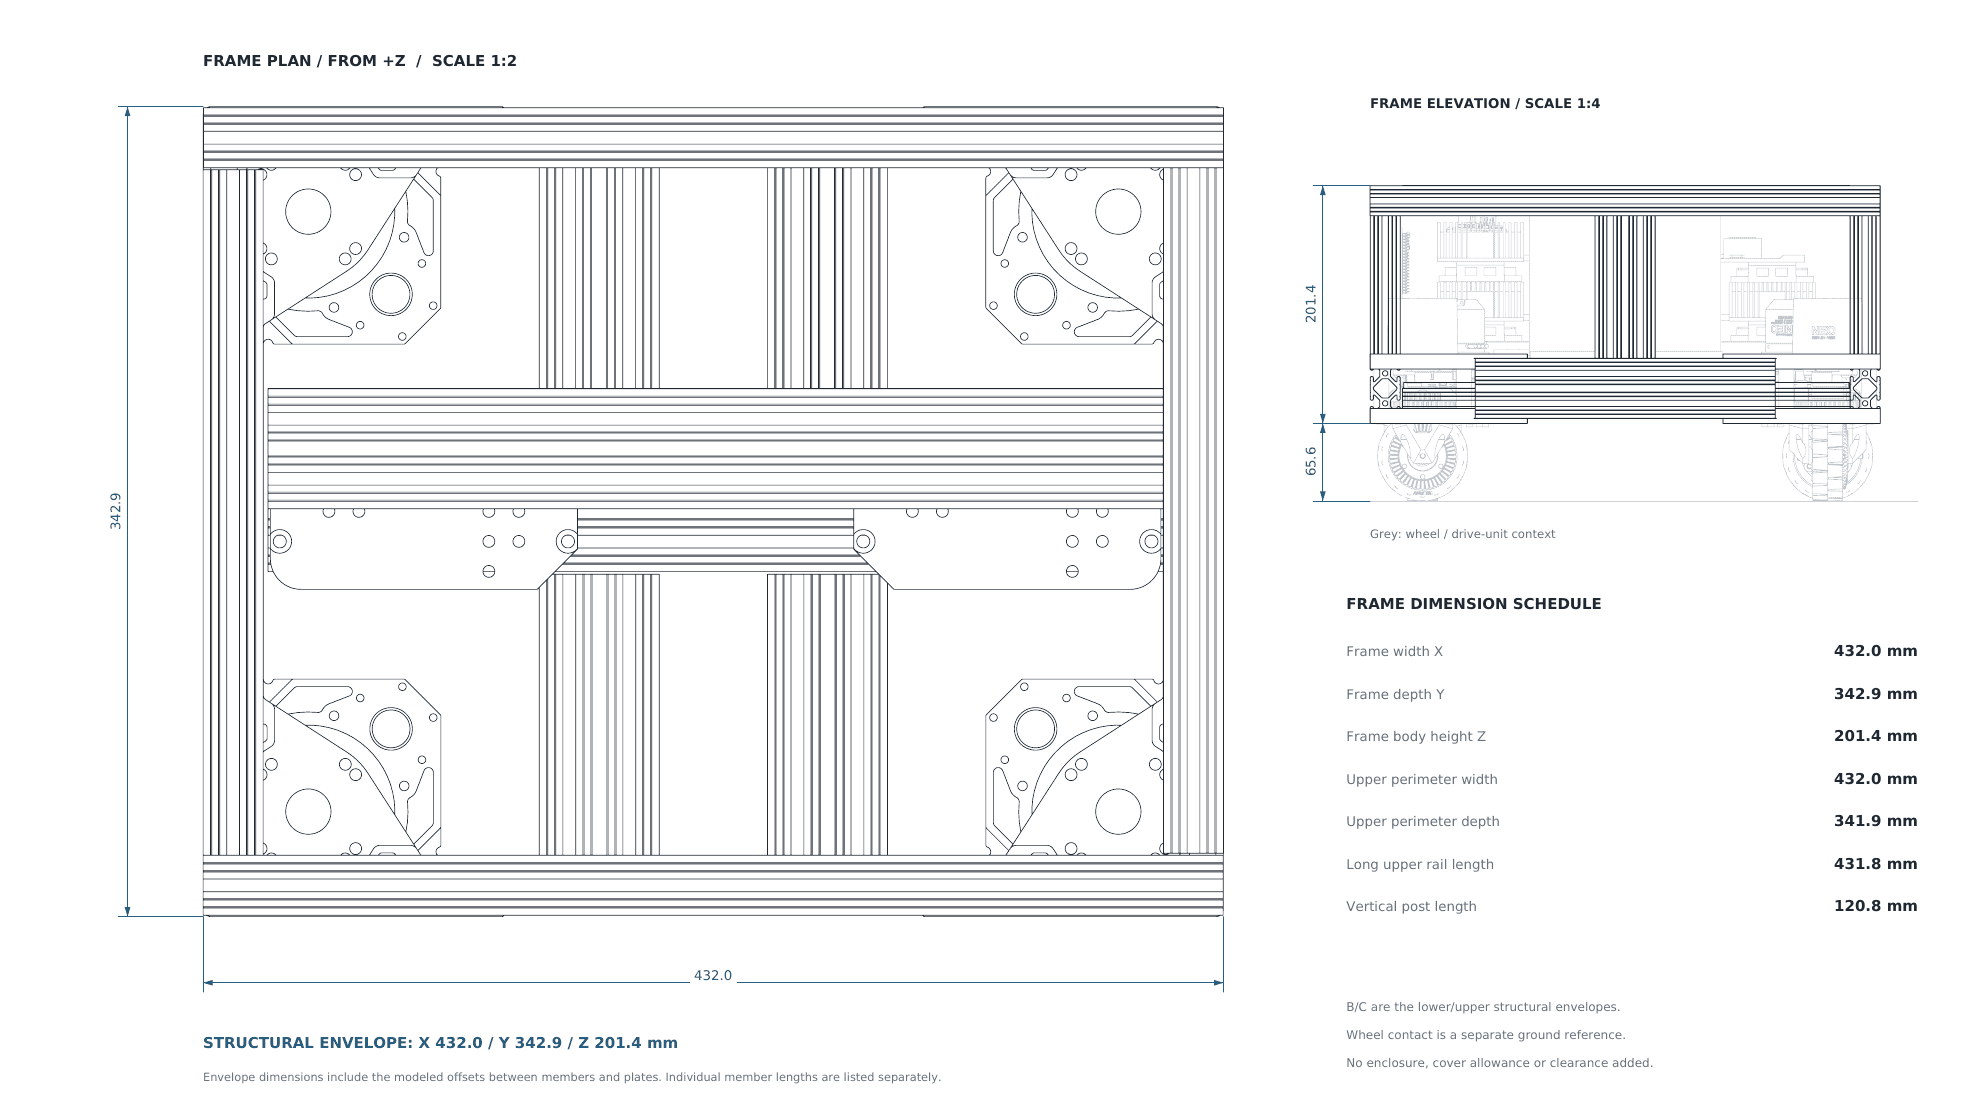
Frame envelope
432.0 × 342.9 × 201.4 mm

Frame body width × depth × height (excluding enclosure and clearance).

Arm mount center height
629.2 mm

Height from ground reference A to arm mounting base center M.

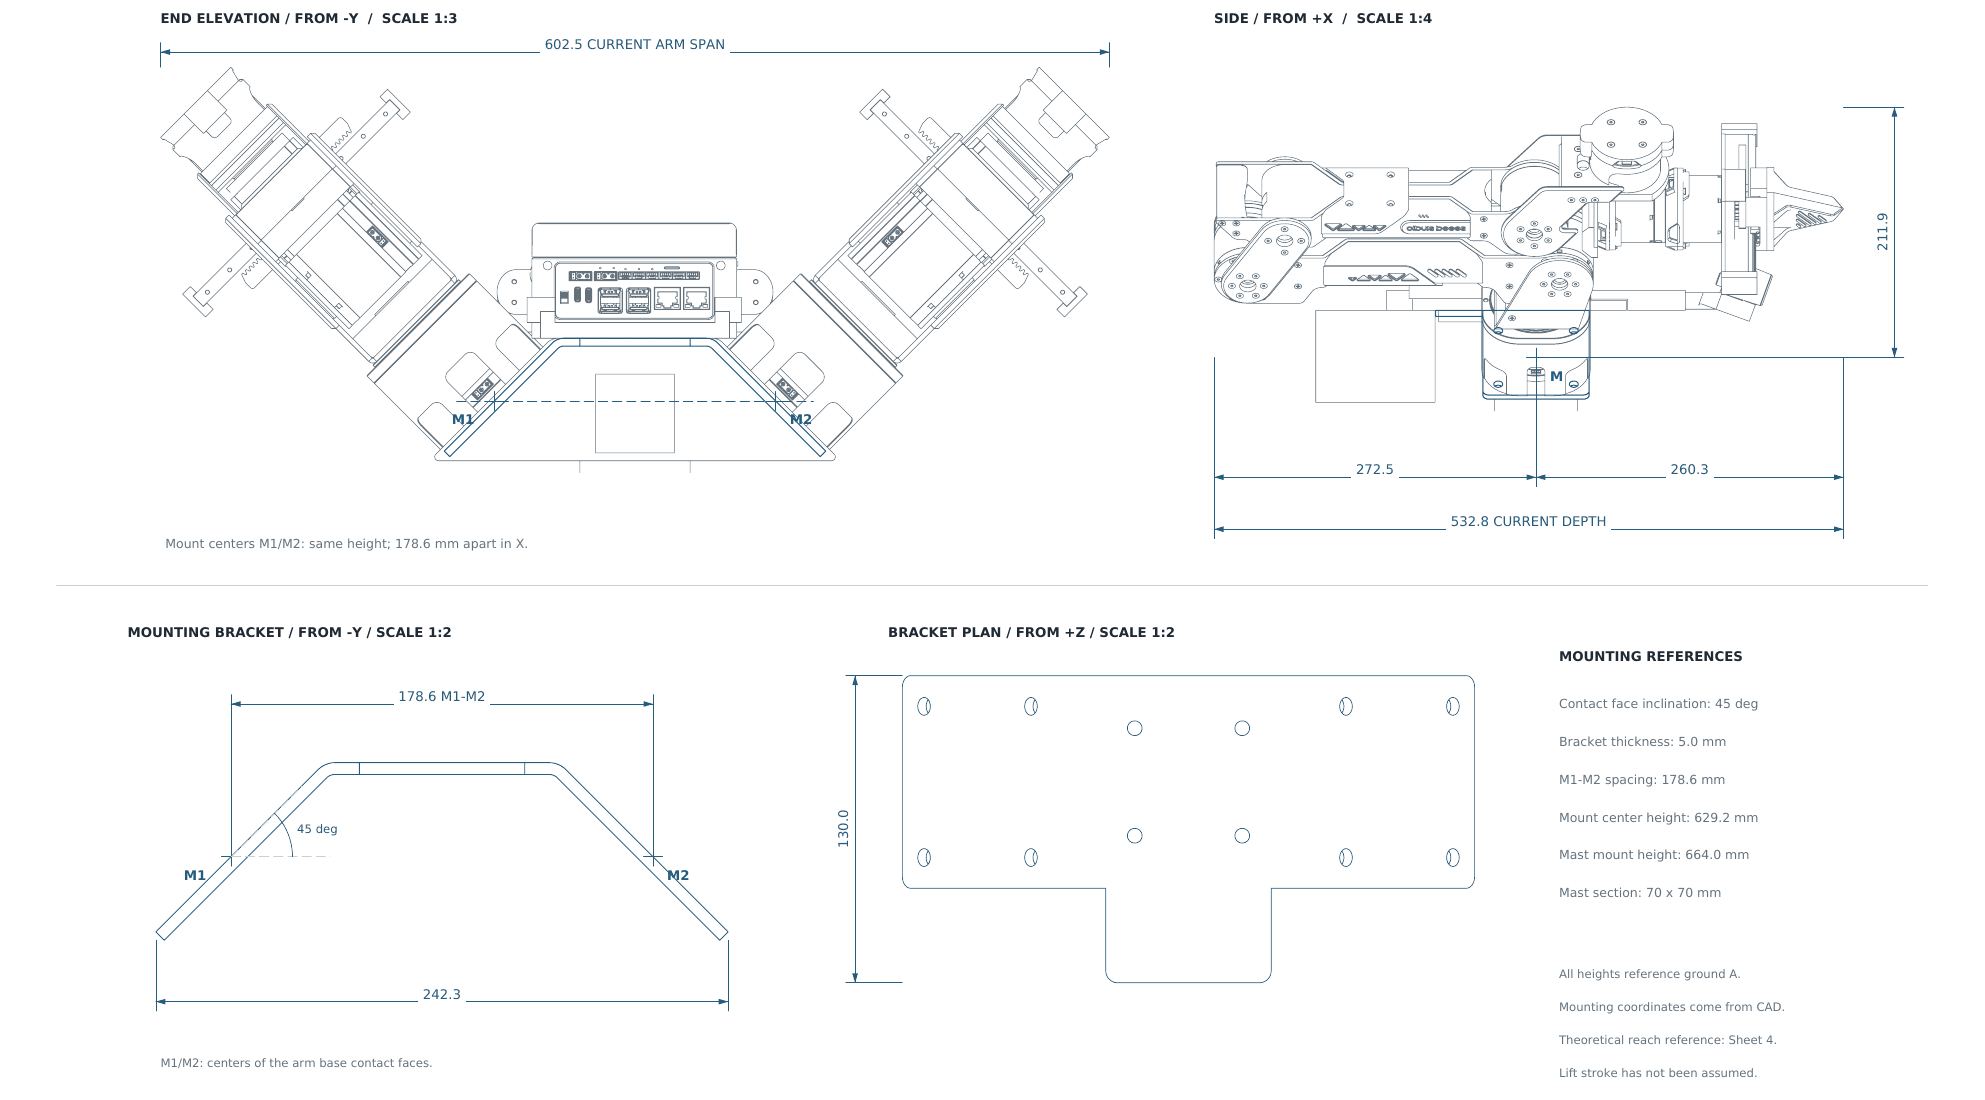
Mount center spacing
178.6 mm

Spacing between left and right arm mount centers (M1–M2) on the 45-degree bracket.

Engineering Drawings

Overall dimensions and height references
Overall Dimensions & Height ReferencesThe drawing defines the height references from ground A. D-C = 397.1 mm is exposed mast height in the shown pose, not a stroke limit.
Chassis frame dimensions and envelope
Chassis Frame DimensionsThis drawing shows the structural frame envelope. Enclosure panels and surrounding clearance are not included.
Upper assembly and arm mounting geometry
Arm Mounting GeometryThe drawing shows the arm mounting positions on the inclined brackets and the folded assembly envelope.
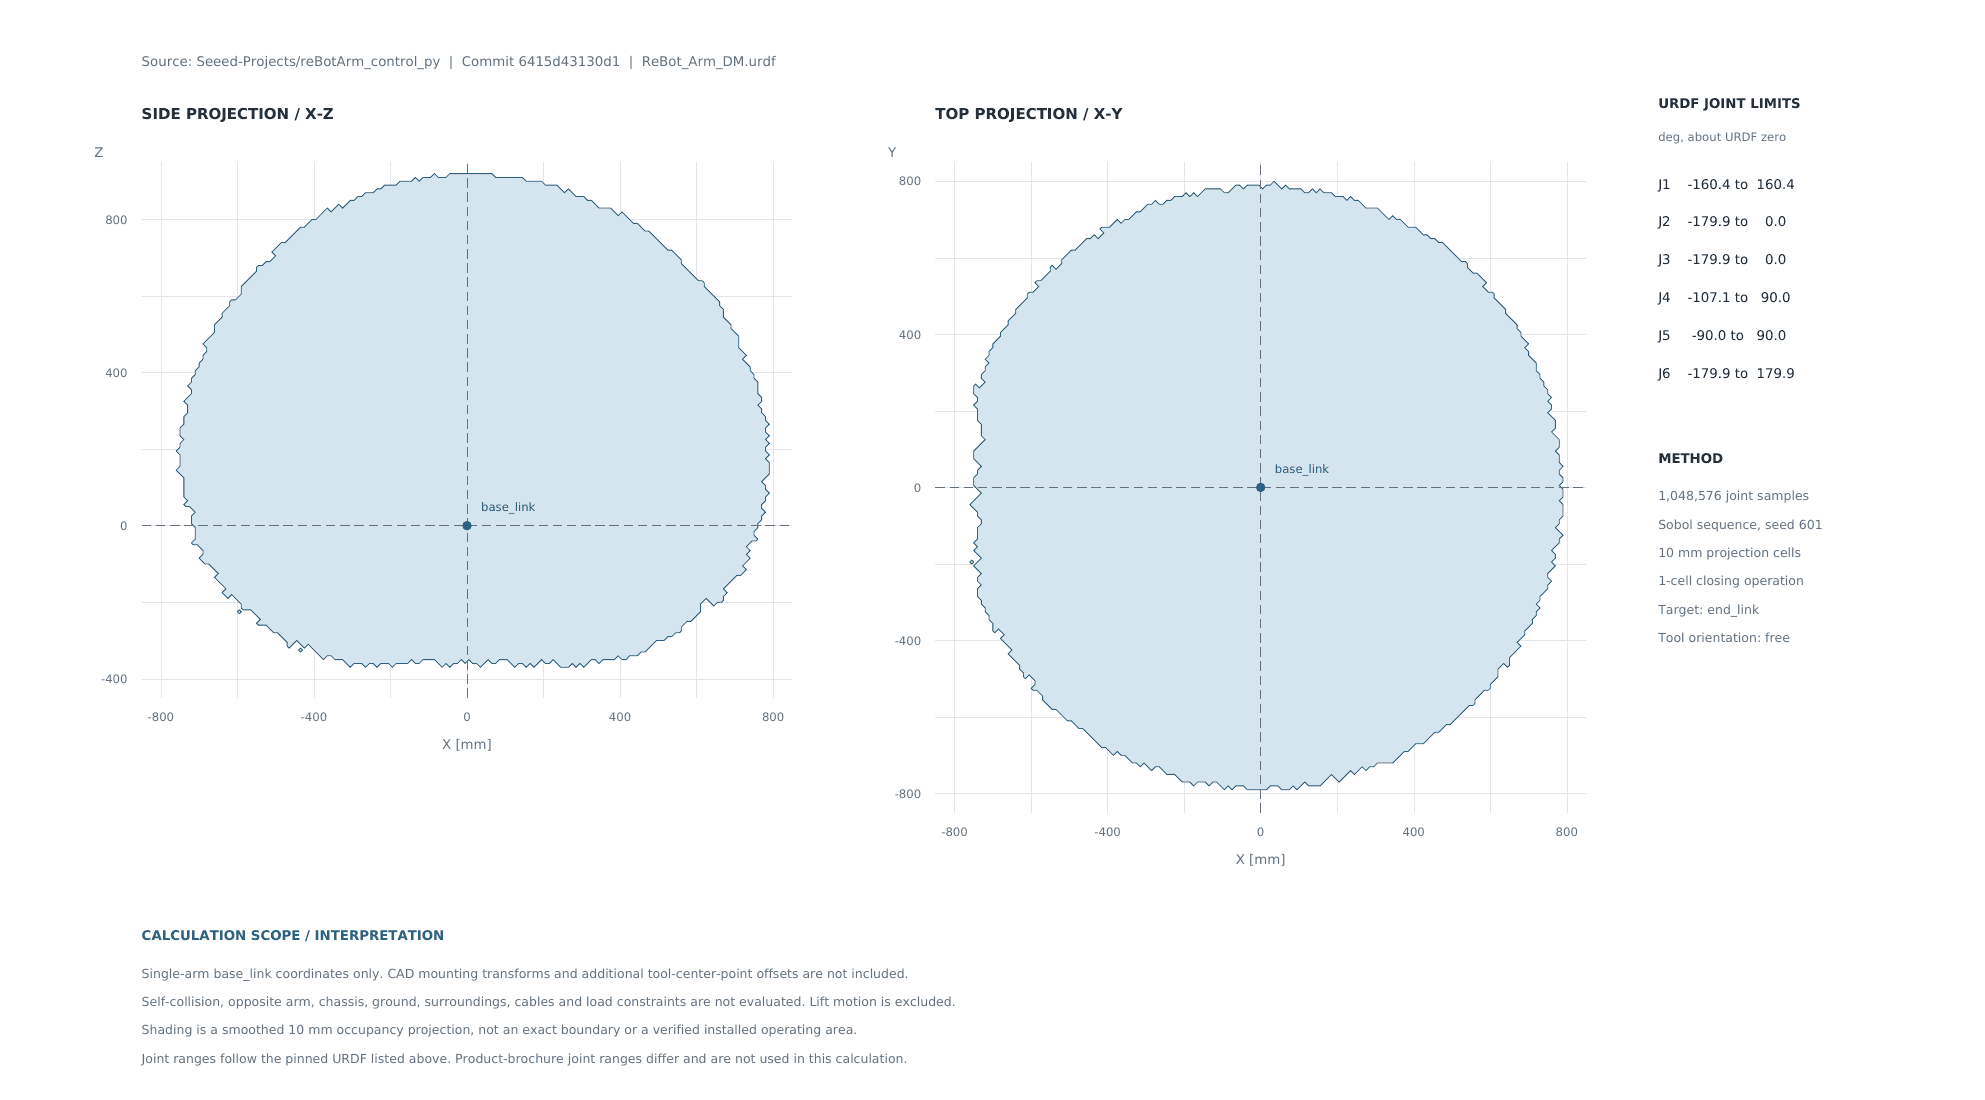
Theoretical single-arm reach envelope analysis
reBot Arm B601-DM Theoretical ReachTheoretical reach for one arm, sampled from 1,048,576 joint poses using the pinned Seeed URDF.

Technical Assets Release Status

ResourceFormatLicenseStatus
Additional CAD & 3D modelsSTEP / STL / CADCERN-OHL-P-2.0In preparation
Robot model v1.0 (URDF + meshes)URDF / STL—Published
Bill of materials (BOM)Google SheetsPublished
Assembly & interface guidesDOCUMENTATION—In preparation

Acquisition options

Two ways to get MY-0

Build MY-0 yourself from open-source designs, or request a quote for a fully assembled and tested unit.

DIY build

From about US$6,300

Parts estimate; varies by configuration and exchange rate.

Source the parts and build from the open-source design. The BOM now links to the mounting plate STEP, and the robot model v1.0 (URDF with meshes) is available. Additional CAD, drawings, and ROS 2 packages are being prepared for release.

Assembled unit

From about US$12,700

USD estimate; varies by exchange rate and configuration.

Two reBot Arm B601-DM arms on the omnidirectional base, fully assembled, calibrated, and tested before shipping. ROS 2 comes set up for research use.

Optional, quoted separately: Additional sensors and cameras, alternate grippers, compute upgrades, and extended support.